
VALERIE22 -- A photorealistic, richly metadata annotated dataset of urban environments
Paper • 2308.09632 • Published
Error code:   ConfigNamesError
Exception:    RuntimeError
Message:      Dataset scripts are no longer supported, but found VALERIE22.py
Traceback:    Traceback (most recent call last):
                File "/src/services/worker/src/worker/job_runners/dataset/config_names.py", line 67, in compute_config_names_response
                  config_names = get_dataset_config_names(
                      path=dataset,
                      token=hf_token,
                  )
                File "/usr/local/lib/python3.14/site-packages/datasets/inspect.py", line 161, in get_dataset_config_names
                  dataset_module = dataset_module_factory(
                      path,
                  ...<4 lines>...
                      **download_kwargs,
                  )
                File "/usr/local/lib/python3.14/site-packages/datasets/load.py", line 1217, in dataset_module_factory
                  raise e1 from None
                File "/usr/local/lib/python3.14/site-packages/datasets/load.py", line 1177, in dataset_module_factory
                  raise RuntimeError(f"Dataset scripts are no longer supported, but found {filename}")
              RuntimeError: Dataset scripts are no longer supported, but found VALERIE22.py
Need help to make the dataset viewer work? Make sure to review how to configure the dataset viewer, and open a discussion for direct support.
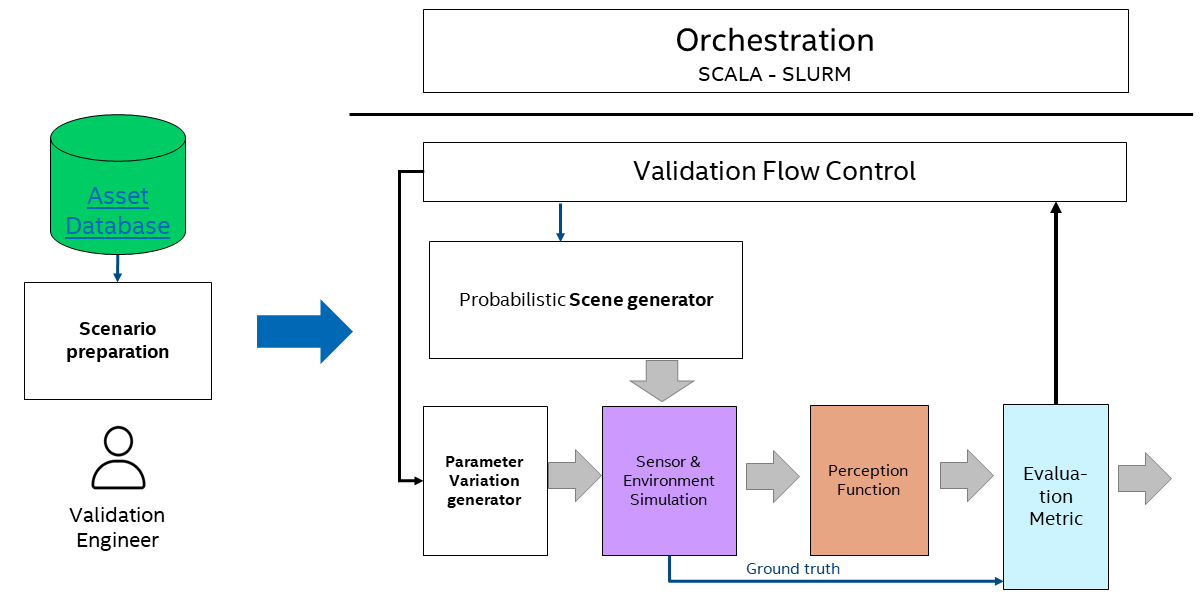
The VALERIE22 dataset was generated with the VALERIE procedural tools pipeline (see image below) providing a photorealistic sensor simulation rendered from automatically synthesized scenes. The dataset provides a uniquely rich set of metadata, allowing extraction of specific scene and semantic features (like pixel-accurate occlusion rates, positions in the scene and distance + angle to the camera). This enables a multitude of possible tests on the data and we hope to stimulate research on understanding performance of DNNs.
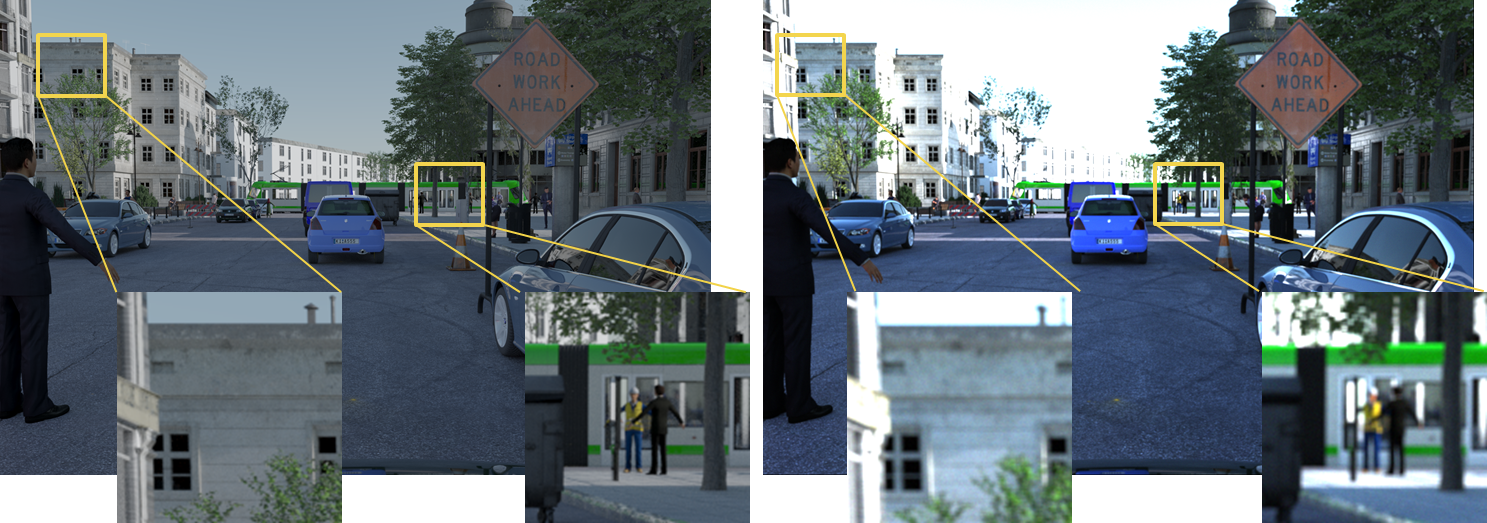
Each sequence of the dataset contains for each scene two rendered images. One is rendered with the default Blender tonemapping (/png) whereas the second is renderd with our photorealistic sensor simulation (see hagn2022optimized). The image below shows the difference of the two methods.
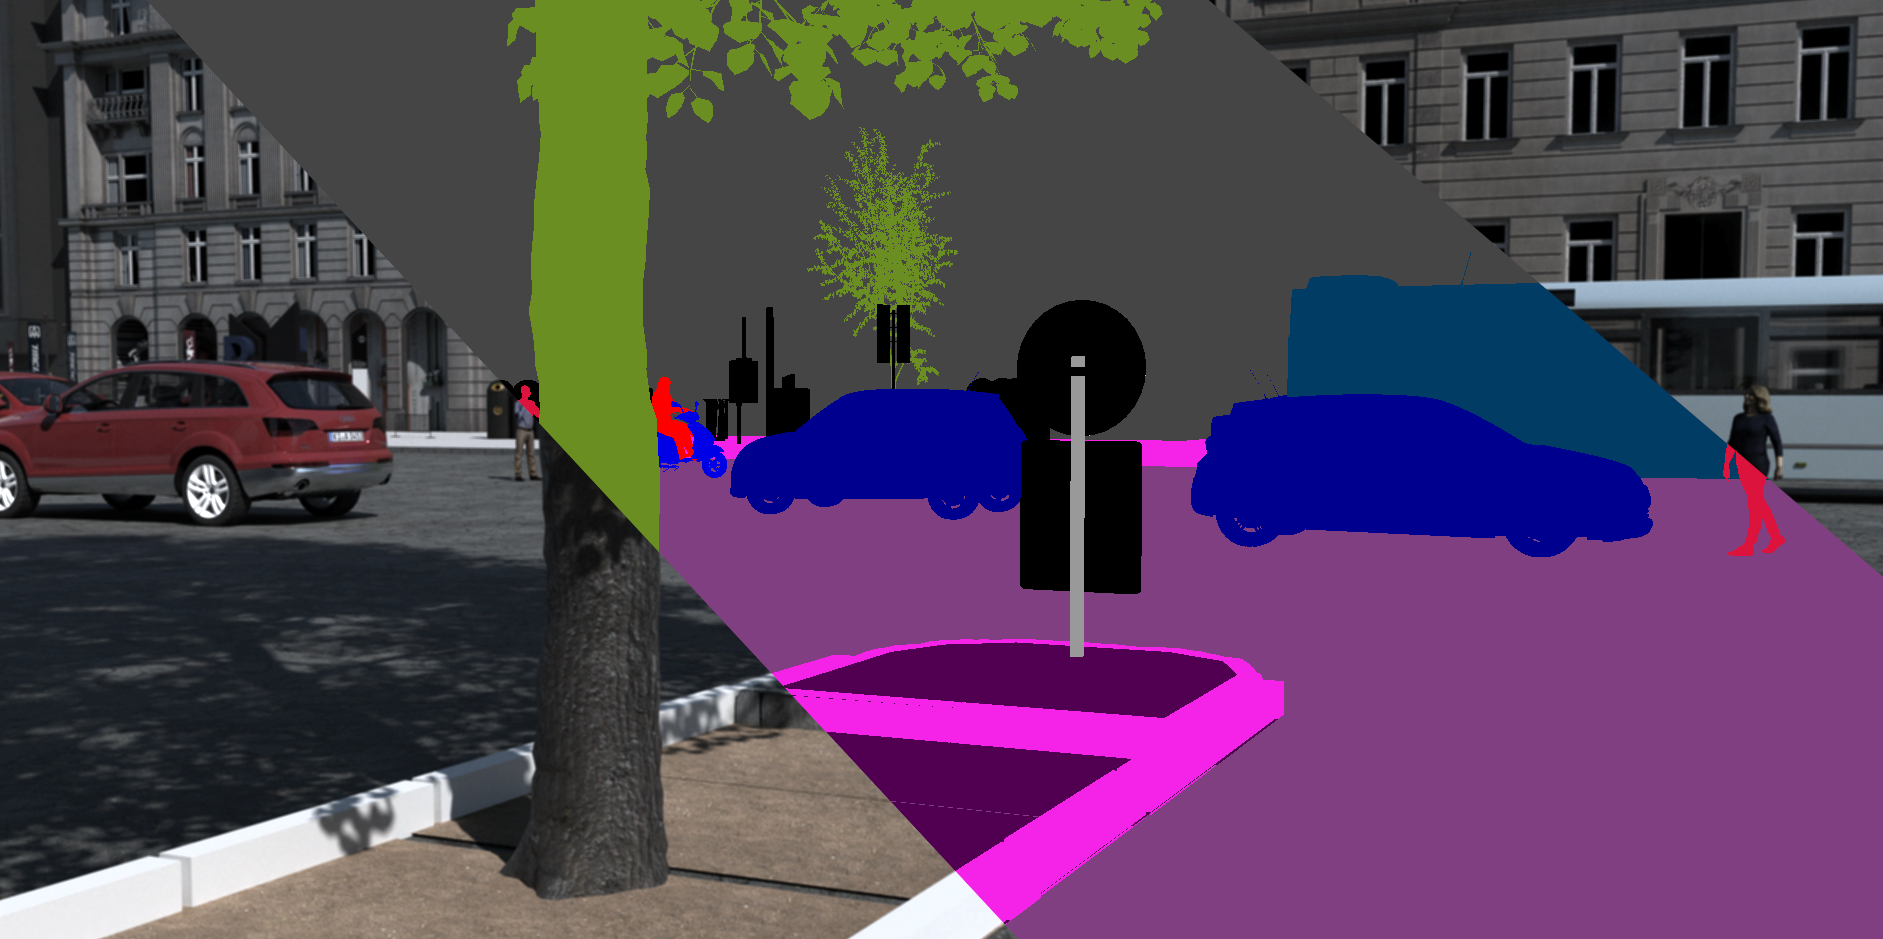
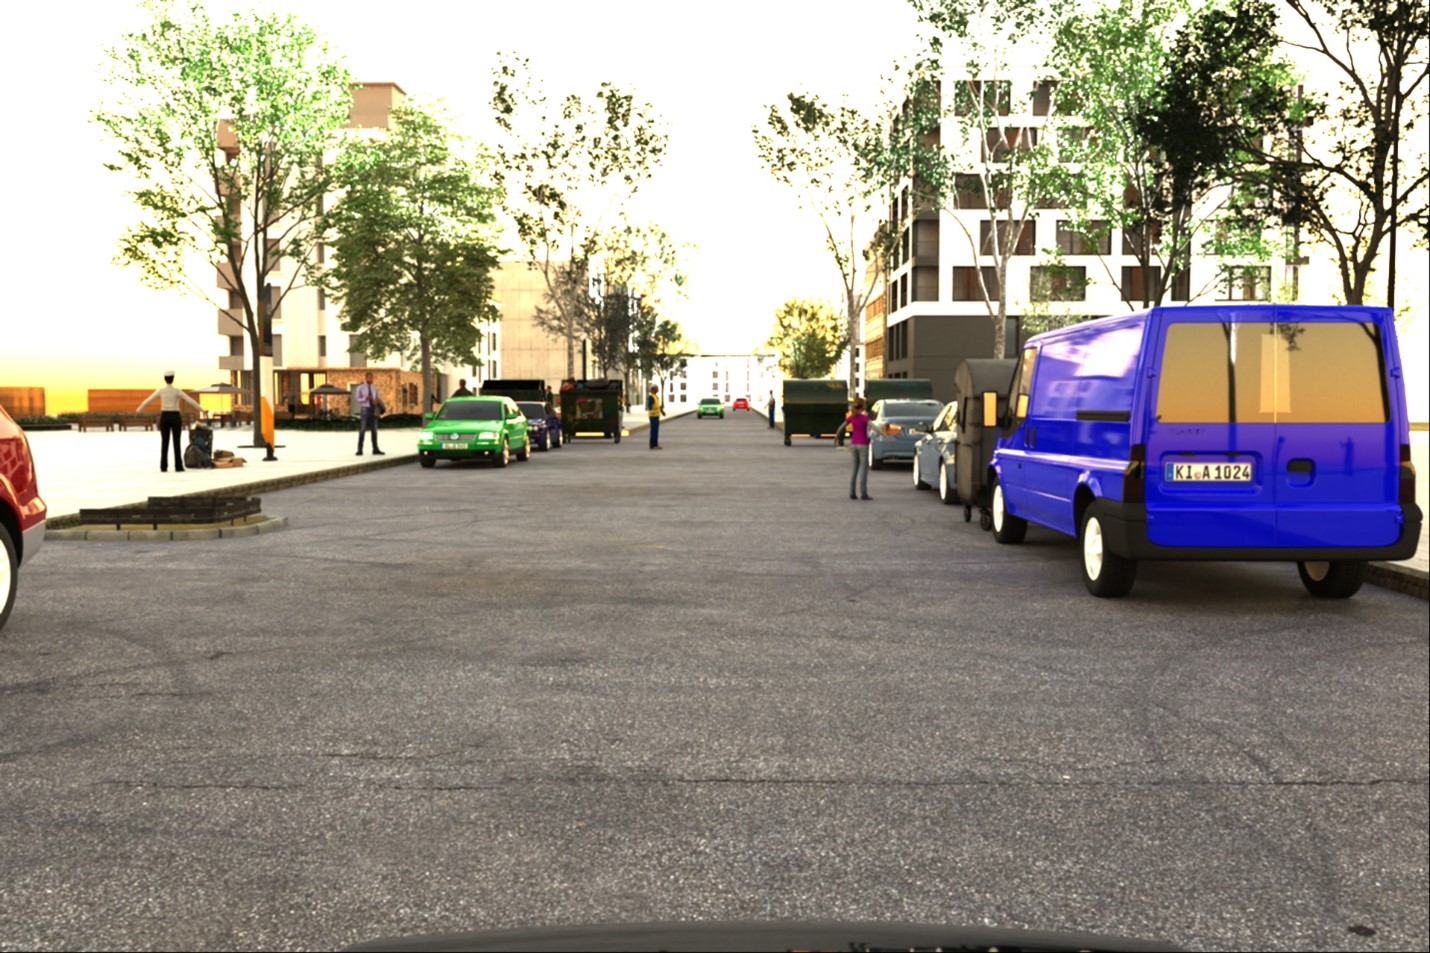
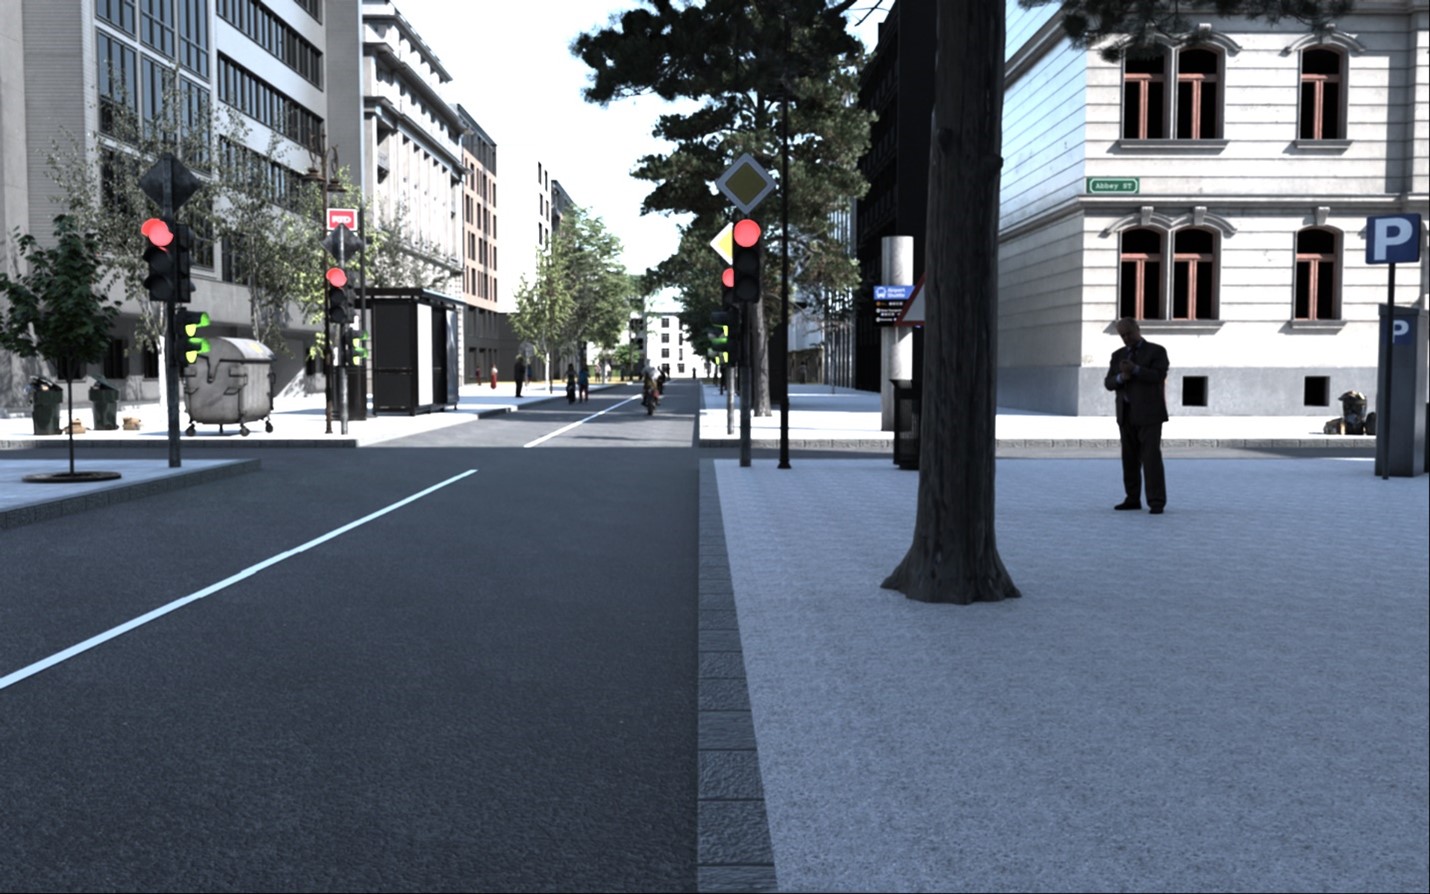
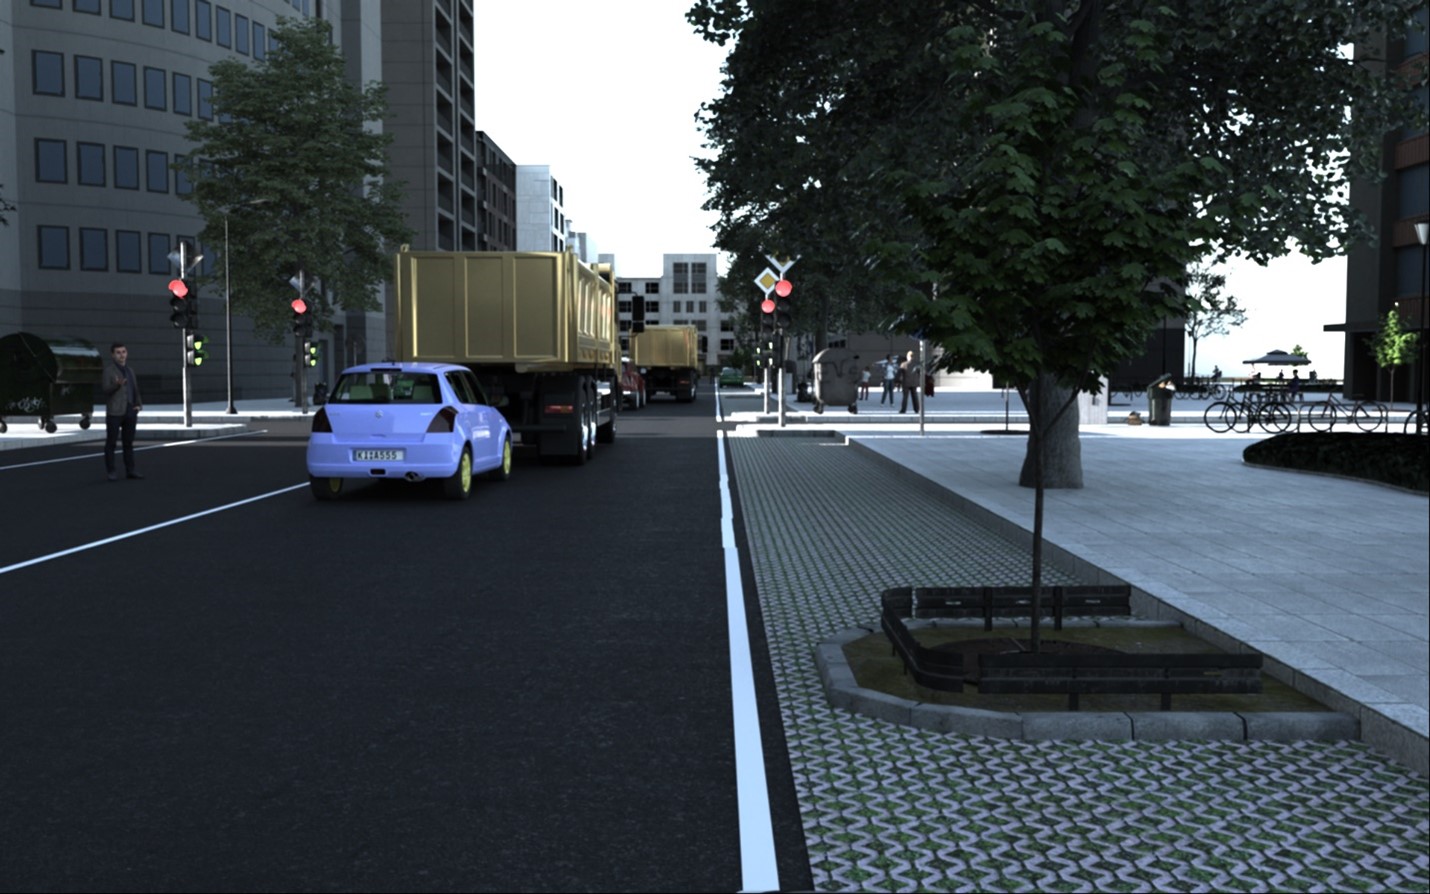
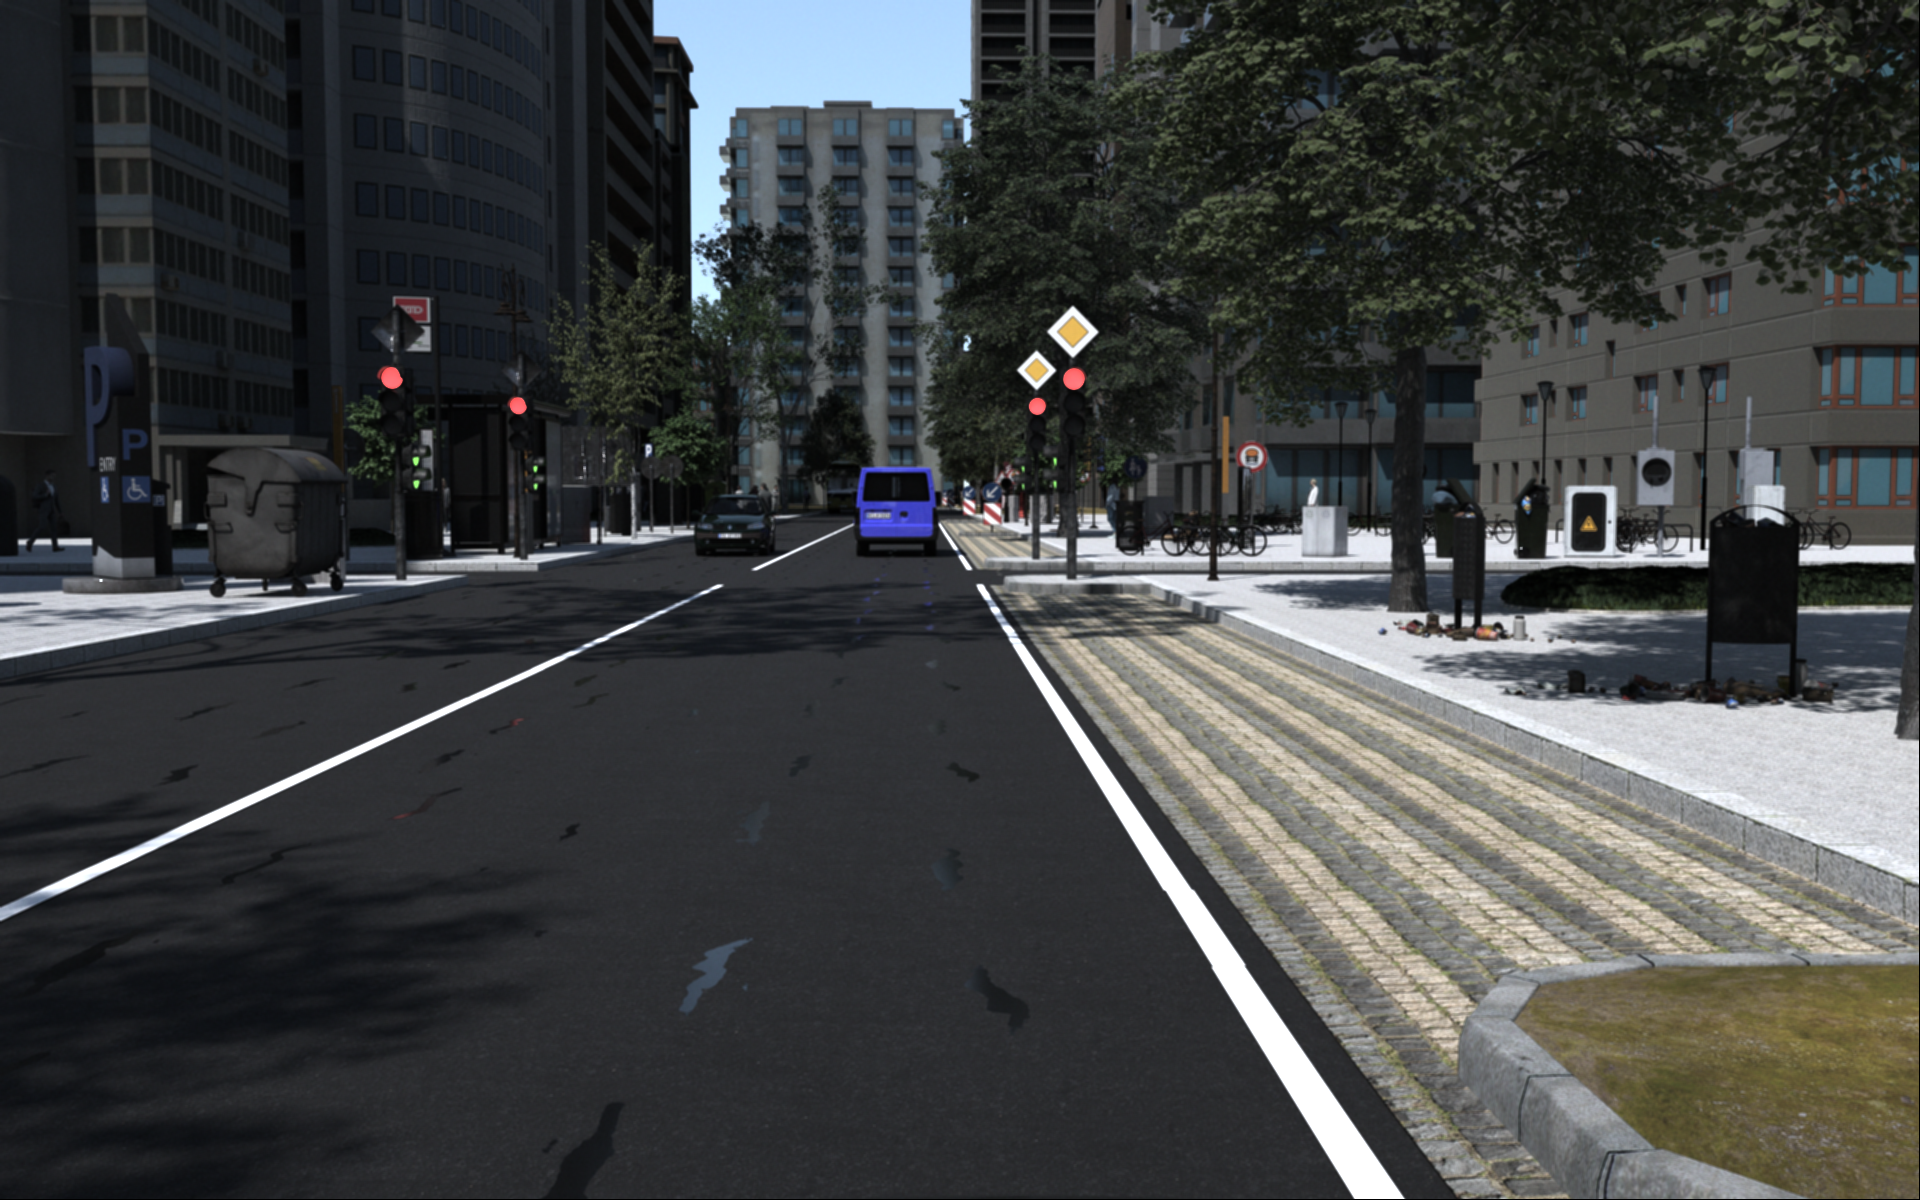
Following are some example images showing the unique characteristics of the different sequences.
| Sequence0052 | Sequence0054 | Sequence0057 | Sequence0058 |
|---|---|---|---|
 |
 |
 |
 |
| Sequence0059 | Sequence0060 | Sequence0062 |
|---|---|---|
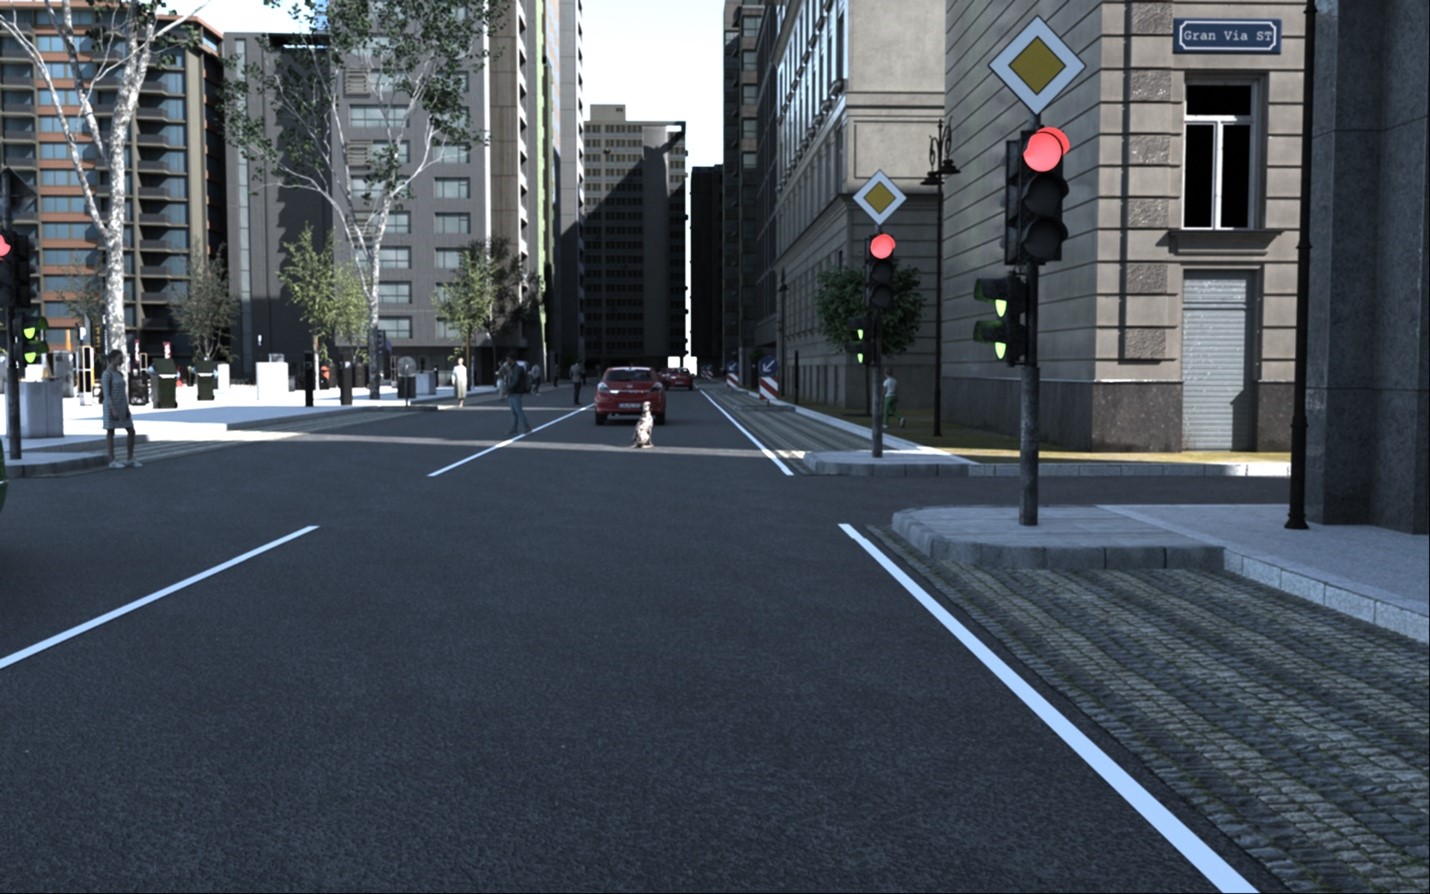 |
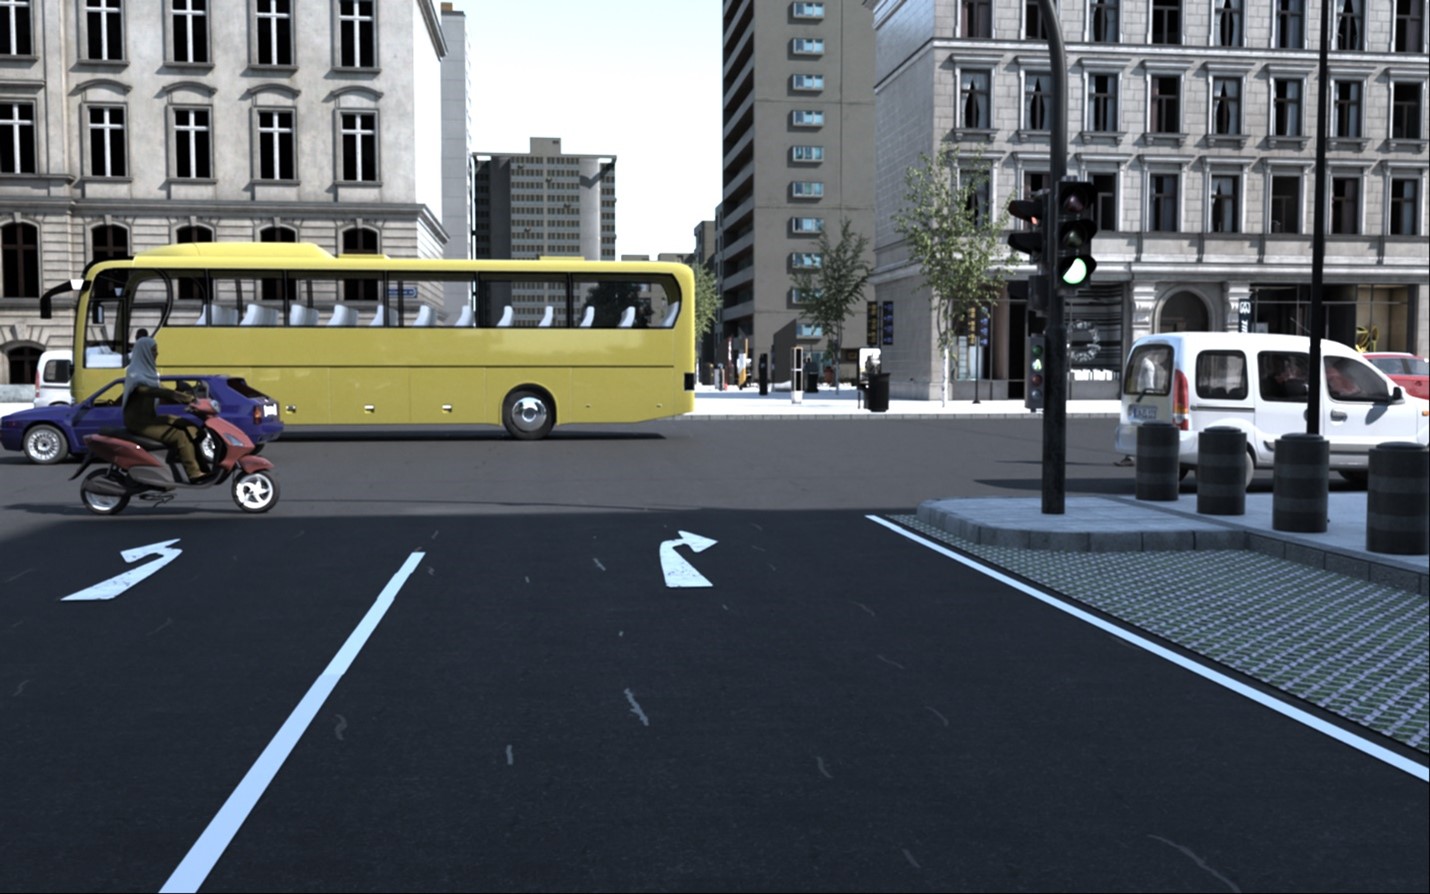 |
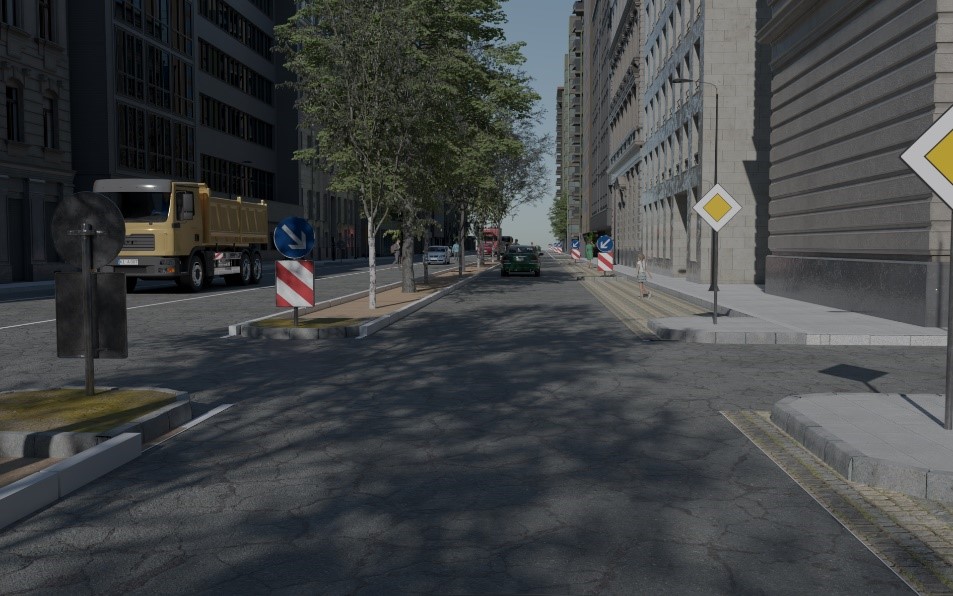 |
VALERIE22
└───intel_results_sequence_0050
│   └───ground-truth
│   │   └───2d-bounding-box_json
│   │   │   └───car-camera000-0000-{UUID}-0000.json
│   │   └───3d-bounding-box_json
│   │   │   └───car-camera000-0000-{UUID}-0000.json
│   │   └───class-id_png
│   │   │   └───car-camera000-0000-{UUID}-0000.png
│   │   └───general-globally-per-frame-analysis_json
│   │   │   └───car-camera000-0000-{UUID}-0000.json
│   │   │   └───car-camera000-0000-{UUID}-0000.csv
│   │   └───semantic-group-segmentation_png
│   │   │   └───car-camera000-0000-{UUID}-0000.png
│   │   └───semantic-instance-segmentation_png
│   │   │   └───car-camera000-0000-{UUID}-0000.png
│   │   │   └───car-camera000-0000-{UUID}-0000
│   │   │   │   └───{Entity-ID}
│   └───sensor
│   │   └───camera
│   │   │   └───left
│   │   │   │   └───png
│   │   │   │   │   └───car-camera000-0000-{UUID}-0000.png
│   │   │   │   └───png_distorted
│   │   │   │   │   └───car-camera000-0000-{UUID}-0000.png
└───intel_results_sequence_0052
└───intel_results_sequence_0054
└───intel_results_sequence_0057
└───intel_results_sequence_0058
└───intel_results_sequence_0059
└───intel_results_sequence_0060
└───intel_results_sequence_0062
13476 images for trainining:
dataset = load_dataset("Intel/VALERIE22", split="train")
8406 images for validation and test:
dataset = load_dataset("Intel/VALERIE22", split="validation")
dataset = load_dataset("Intel/VALERIE22", split="test")
CC BY 4.0
Generated within project KI-Abischerung with funding of the German Federal Ministry of Industry and Energy under grant number 19A19005M.
Relevant publications:
@misc{grau2023valerie22,
    title={VALERIE22 -- A photorealistic, richly metadata annotated dataset of urban environments},
    author={Oliver Grau and Korbinian Hagn},
    year={2023},
    eprint={2308.09632},
    archivePrefix={arXiv},
    primaryClass={cs.CV}
}

@inproceedings{hagn2022increasing,
  title={Increasing pedestrian detection performance through weighting of detection impairing factors},
  author={Hagn, Korbinian and Grau, Oliver},
  booktitle={Proceedings of the 6th ACM Computer Science in Cars Symposium},
  pages={1--10},
  year={2022}
}

@inproceedings{hagn2022validation,
  title={Validation of Pedestrian Detectors by Classification of Visual Detection Impairing Factors},
  author={Hagn, Korbinian and Grau, Oliver},
  booktitle={European Conference on Computer Vision},
  pages={476--491},
  year={2022},
  organization={Springer}
}

@incollection{grau2022variational,
  title={A variational deep synthesis approach for perception validation},
  author={Grau, Oliver and Hagn, Korbinian and Syed Sha, Qutub},
  booktitle={Deep Neural Networks and Data for Automated Driving: Robustness, Uncertainty Quantification, and Insights Towards Safety},
  pages={359--381},
  year={2022},
  publisher={Springer International Publishing Cham}
}

@incollection{hagn2022optimized,
  title={Optimized data synthesis for DNN training and validation by sensor artifact simulation},
  author={Hagn, Korbinian and Grau, Oliver},
  booktitle={Deep Neural Networks and Data for Automated Driving: Robustness, Uncertainty Quantification, and Insights Towards Safety},
  pages={127--147},
  year={2022},
  publisher={Springer International Publishing Cham}
}

@inproceedings{syed2020dnn,
  title={DNN analysis through synthetic data variation},
  author={Syed Sha, Qutub and Grau, Oliver and Hagn, Korbinian},
  booktitle={Proceedings of the 4th ACM Computer Science in Cars Symposium},
  pages={1--10},
  year={2020}
}