

NoDrift3R: Raymap-Guided Coupling for Drift-Robust Unposed Feed-Forward 3D Reconstruction
Paper • 2607.07168 • Published • 1
Project Page | Paper | Code
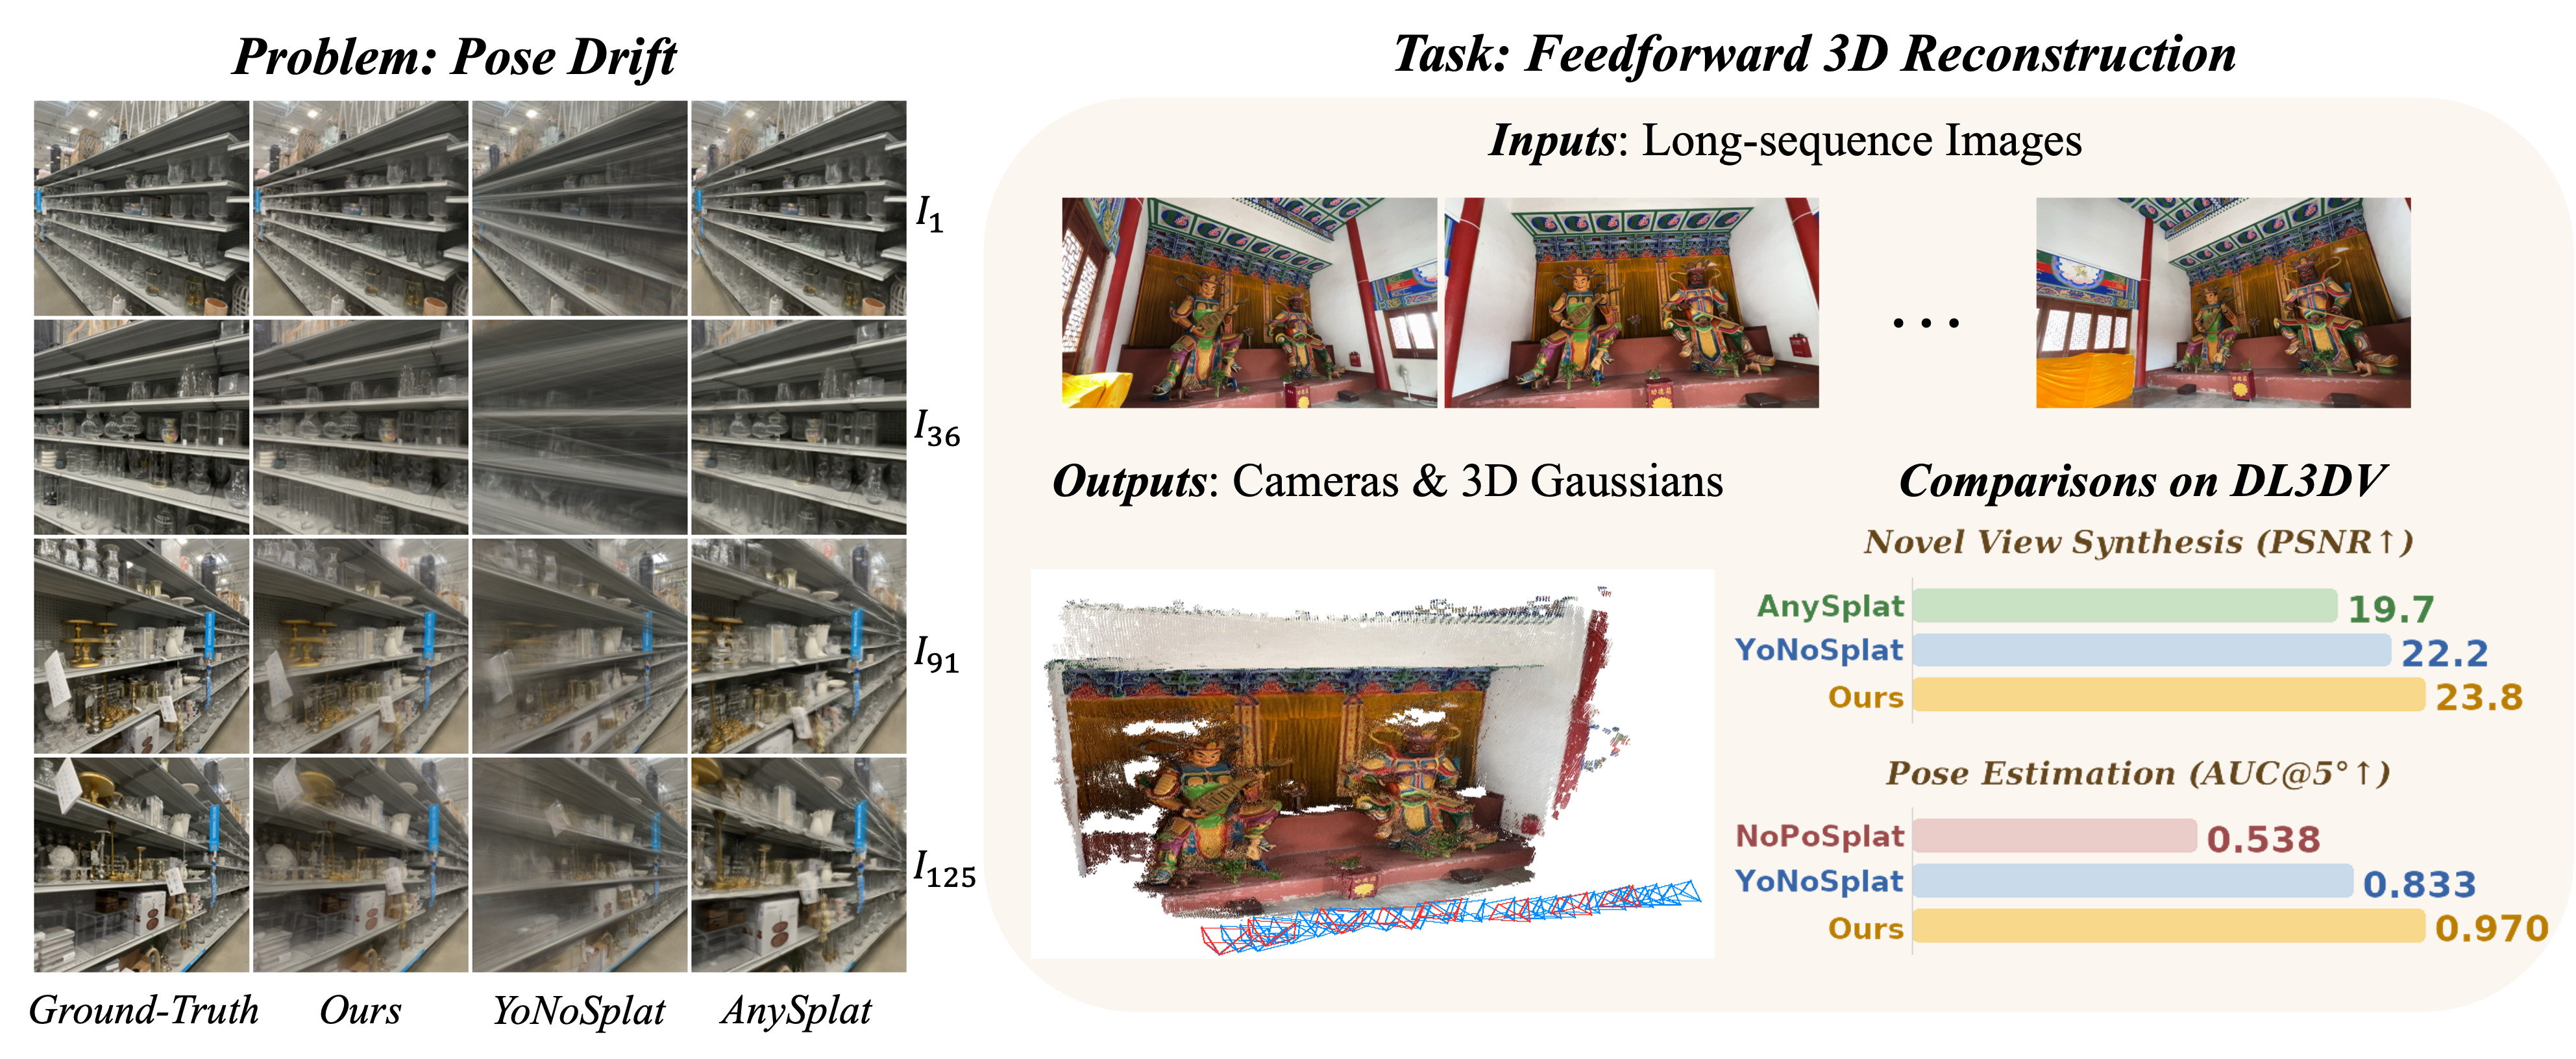
NoDrift3R is an ECCV 2026 method for drift-robust, pose-free feed-forward 3D Gaussian Splatting reconstruction. It targets cumulative camera-pose drift in long, unposed image sequences by explicitly coupling geometry and appearance. Gaussian centers are anchored to raymap-induced geometry, while RGB reconstruction, raymap consistency, and camera regularization are optimized jointly to improve rendering, geometry, and pose estimation together.
This repository contains the following checkpoints:
dl3dv_giant_2_8_H20.ckptdl3dv_large_4_8_5090.ckptmix_dataset_giant_4_8_H20.ckptmix_dataset_large_8_8_5090.ckptPlease follow the GitHub repository and project page for code, configuration, dataset, and usage updates.
If you find NoDrift3R useful in your research, please cite:
@misc{sun2026nodrift3rraymapguidedcouplingdriftrobust,
  title         = {NoDrift3R: Raymap-Guided Coupling for Drift-Robust Unposed Feed-Forward 3D Reconstruction},
  author        = {Xiangyu Sun and Liu Liu and Seungkwon Yang and Jingbing Han and Seungtae Nam and Zhizhong Su and Eunbyung Park},
  year          = {2026},
  eprint        = {2607.07168},
  archivePrefix = {arXiv},
  primaryClass  = {cs.CV},
  url           = {https://arxiv.org/abs/2607.07168}
}